I'll be at Stanford DroneHacks 2026
August 15th, 2026 / Stanford, California
I was accepted into Stanford University's first ever aerial robotics hackathon, Stanford DroneHacks! This is an intensive three-day event where students from across North America are flown out to California to develop autonomous drones from the ground up. Teams receive identical hardware and are tasked with designing, training, and deploying a complete perception, navigation, and decision-making stack capable of agile GPS-denied flight. Participants compete for $15,000 in prizes while receiving mentorship from industry leaders in autonomy.
Huge thanks to Colin Balfour, Rohan Inamdar, and Rohan Walia for teaming up with me for this challenge.
I look forward to hacking alongside everyone this November, and best of luck to all teams!
Event-based MAV Navigation in Dense Cluttered Environments
May 6th, 2026 / Worcester, Massachusetts
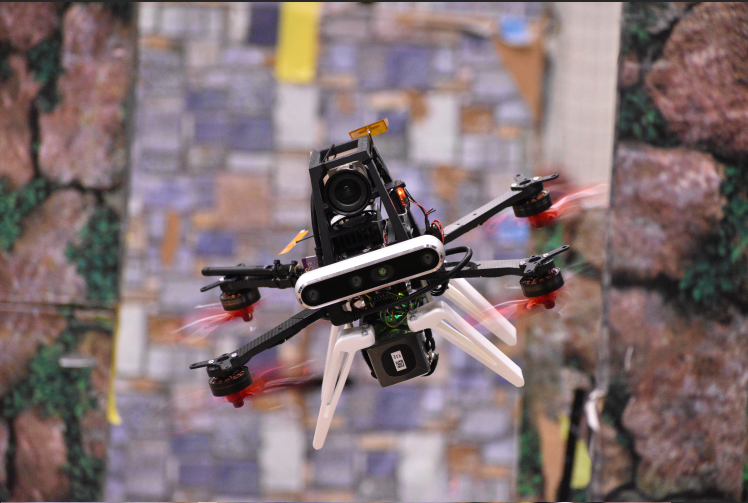
For our Worcester Polytechnic Institute Robotics Engineering Major Qualifying Project (MQP), we designed and built a full autonomy stack and custom quadrotor equipped with state-of-the-art neuromorphic event cameras for autonomous high-speed flight through dense, cluttered environments.
Special thanks to my partners Colin Balfour and Rohan Inamdar, and our project advisors Nitin J. Sanket and Guanrui Li for their guidance throughout this project.
Awards: Best MQP Finalist 2026
Links: Video / Poster / Report